Hip Joint Motors
The hip is the most heavily loaded joint in a humanoid robot. It carries the robot's whole weight, takes an impact with every step and keeps holding the load while standing.
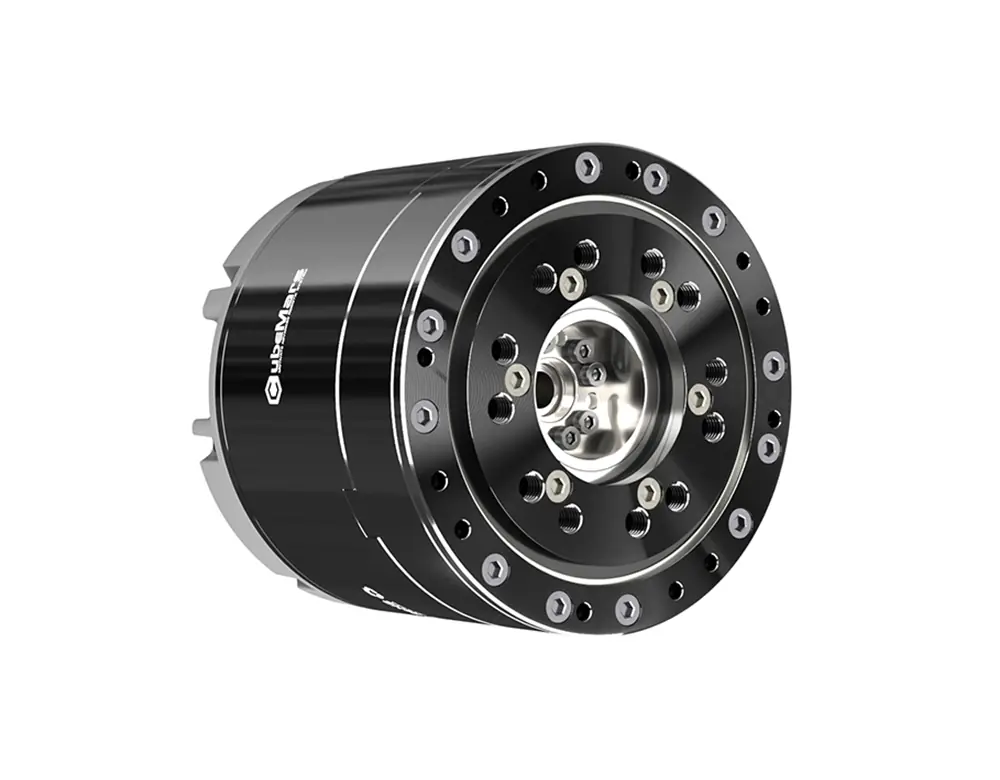
For this joint we recommend the CubeMars AKH70-48 V1.0 KV41. Rated torque 74 Nm, peak torque 222 Nm and KV 41 rpm/V.
Hip torque grows quickly with the robot's total mass and stride length. If you tell us your robot's weight and target walking speed, we can work out the required value together.
If you are also choosing the knee and ankle motors, you can compare the models we recommend for the whole leg in our joint selector.
Choosing a motor
The most common questions when comparing products in this category.
What is the difference between rated and peak torque?
Rated torque is what the motor can deliver continuously without overheating, so size your system to it. Peak torque is the upper limit it can withstand for short periods. Look at peak torque for starts and impacts, and rated torque for continuous operation.
What does the KV value mean?
KV is the number of revolutions per volt. A low KV means more torque and less speed, and a high KV the opposite. With the same frame, the KV choice sets the speed and torque balance of your application.
How should I choose the gear ratio?
A gearbox increases torque and reduces speed. Applications that need high torque at low speed, like a legged robot joint, favor a high ratio (36:1, 48:1), and those that need fast response favor a low ratio (6:1, 9:1). If you are not sure, send us your target torque and speed.
Frameless motor or integrated actuator?
In integrated actuators (AK, AKH) the driver, encoder and gearbox are inside the motor, and they run over CAN straight out of the box. The AKE series combines motor and gearbox and uses an external driver. Frameless motors (RI, RO) are just a rotor and stator that you build into your own mechanics, and they need an external driver. Choose frameless for tight spaces or custom designs, and integrated for quick installation.
How do I use the filters?
In the filter panel you can narrow down by series, gear ratio, peak torque, KV, no-load speed, weight and price. On desktop the panel sits to the left of the list, and on mobile it opens with the Filter button. Products without a value for a filter drop out when you apply it, so we recommend starting broad and narrowing step by step.
Not sure which to choose?Ask the technical team